
HC-SR04 Distance Measurement (Serial Display)

Video
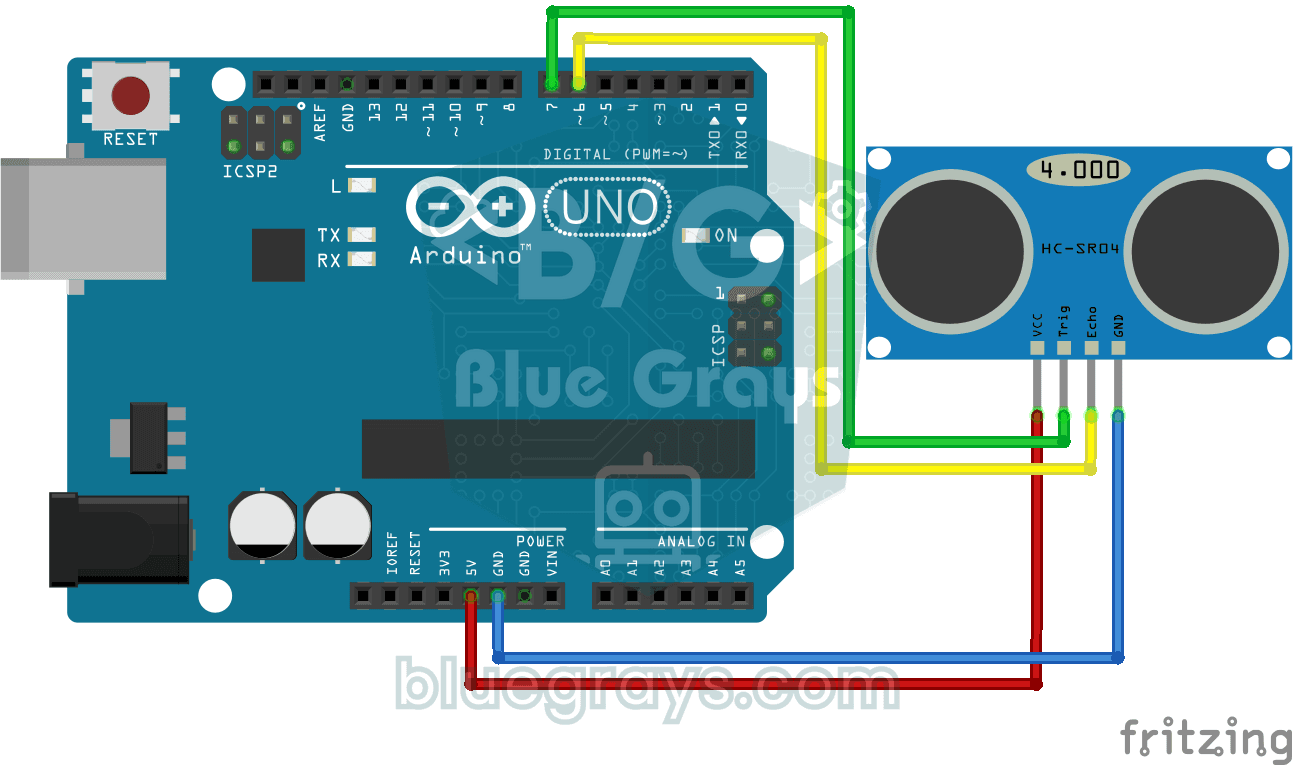
Elektr sxemasi
Manba kodi
1// ─────────────────────────────────────────
2//   BlueGrays · bluegrays.com
3//   HC-SR04 Distance Measurement (Serial Display)
4// ─────────────────────────────────────────
5// Measures distance with the HC-SR04 ultrasonic sensor and prints results
6// between 3 and 100 cm to the Serial Monitor in cm every 0.5 s.
7//
8// Pins:
9//   D7 -> HC-SR04 Trig
10//   D6 -> HC-SR04 Echo
11//   HC-SR04 VCC to 5V, GND to GND
12
13int echoPin = 6;        // Echo input
14int trigPin = 7;        // Trigger output
15int maxDistance = 100;  // Largest distance shown (cm)
16int minDistance = 3;    // Smallest distance shown (cm)
17
18void setup() {
19  pinMode(trigPin, OUTPUT);
20  pinMode(echoPin, INPUT);
21  Serial.begin(9600);
22}
23
24void loop() {
25  // A 10 us trigger pulse sends the sound burst
26  digitalWrite(trigPin, HIGH);
27  delayMicroseconds(10);
28  digitalWrite(trigPin, LOW);
29
30  // How long Echo stays HIGH (us) is the round-trip time. Sound travels at 0.034 cm/us; halving the
31  // path gives the distance
32  unsigned long duration = pulseIn(echoPin, HIGH);
33  double totalPath = (double)duration * 0.034;
34  int distance = totalPath / 2;
35
36  // Print only inside the valid range
37  if (distance > minDistance && distance < maxDistance) {
38    Serial.print("Distance: ");
39    Serial.print(distance);
40    Serial.println("cm");
41  }
42
43  delay(500);   // Wait 0.5 s
44}
45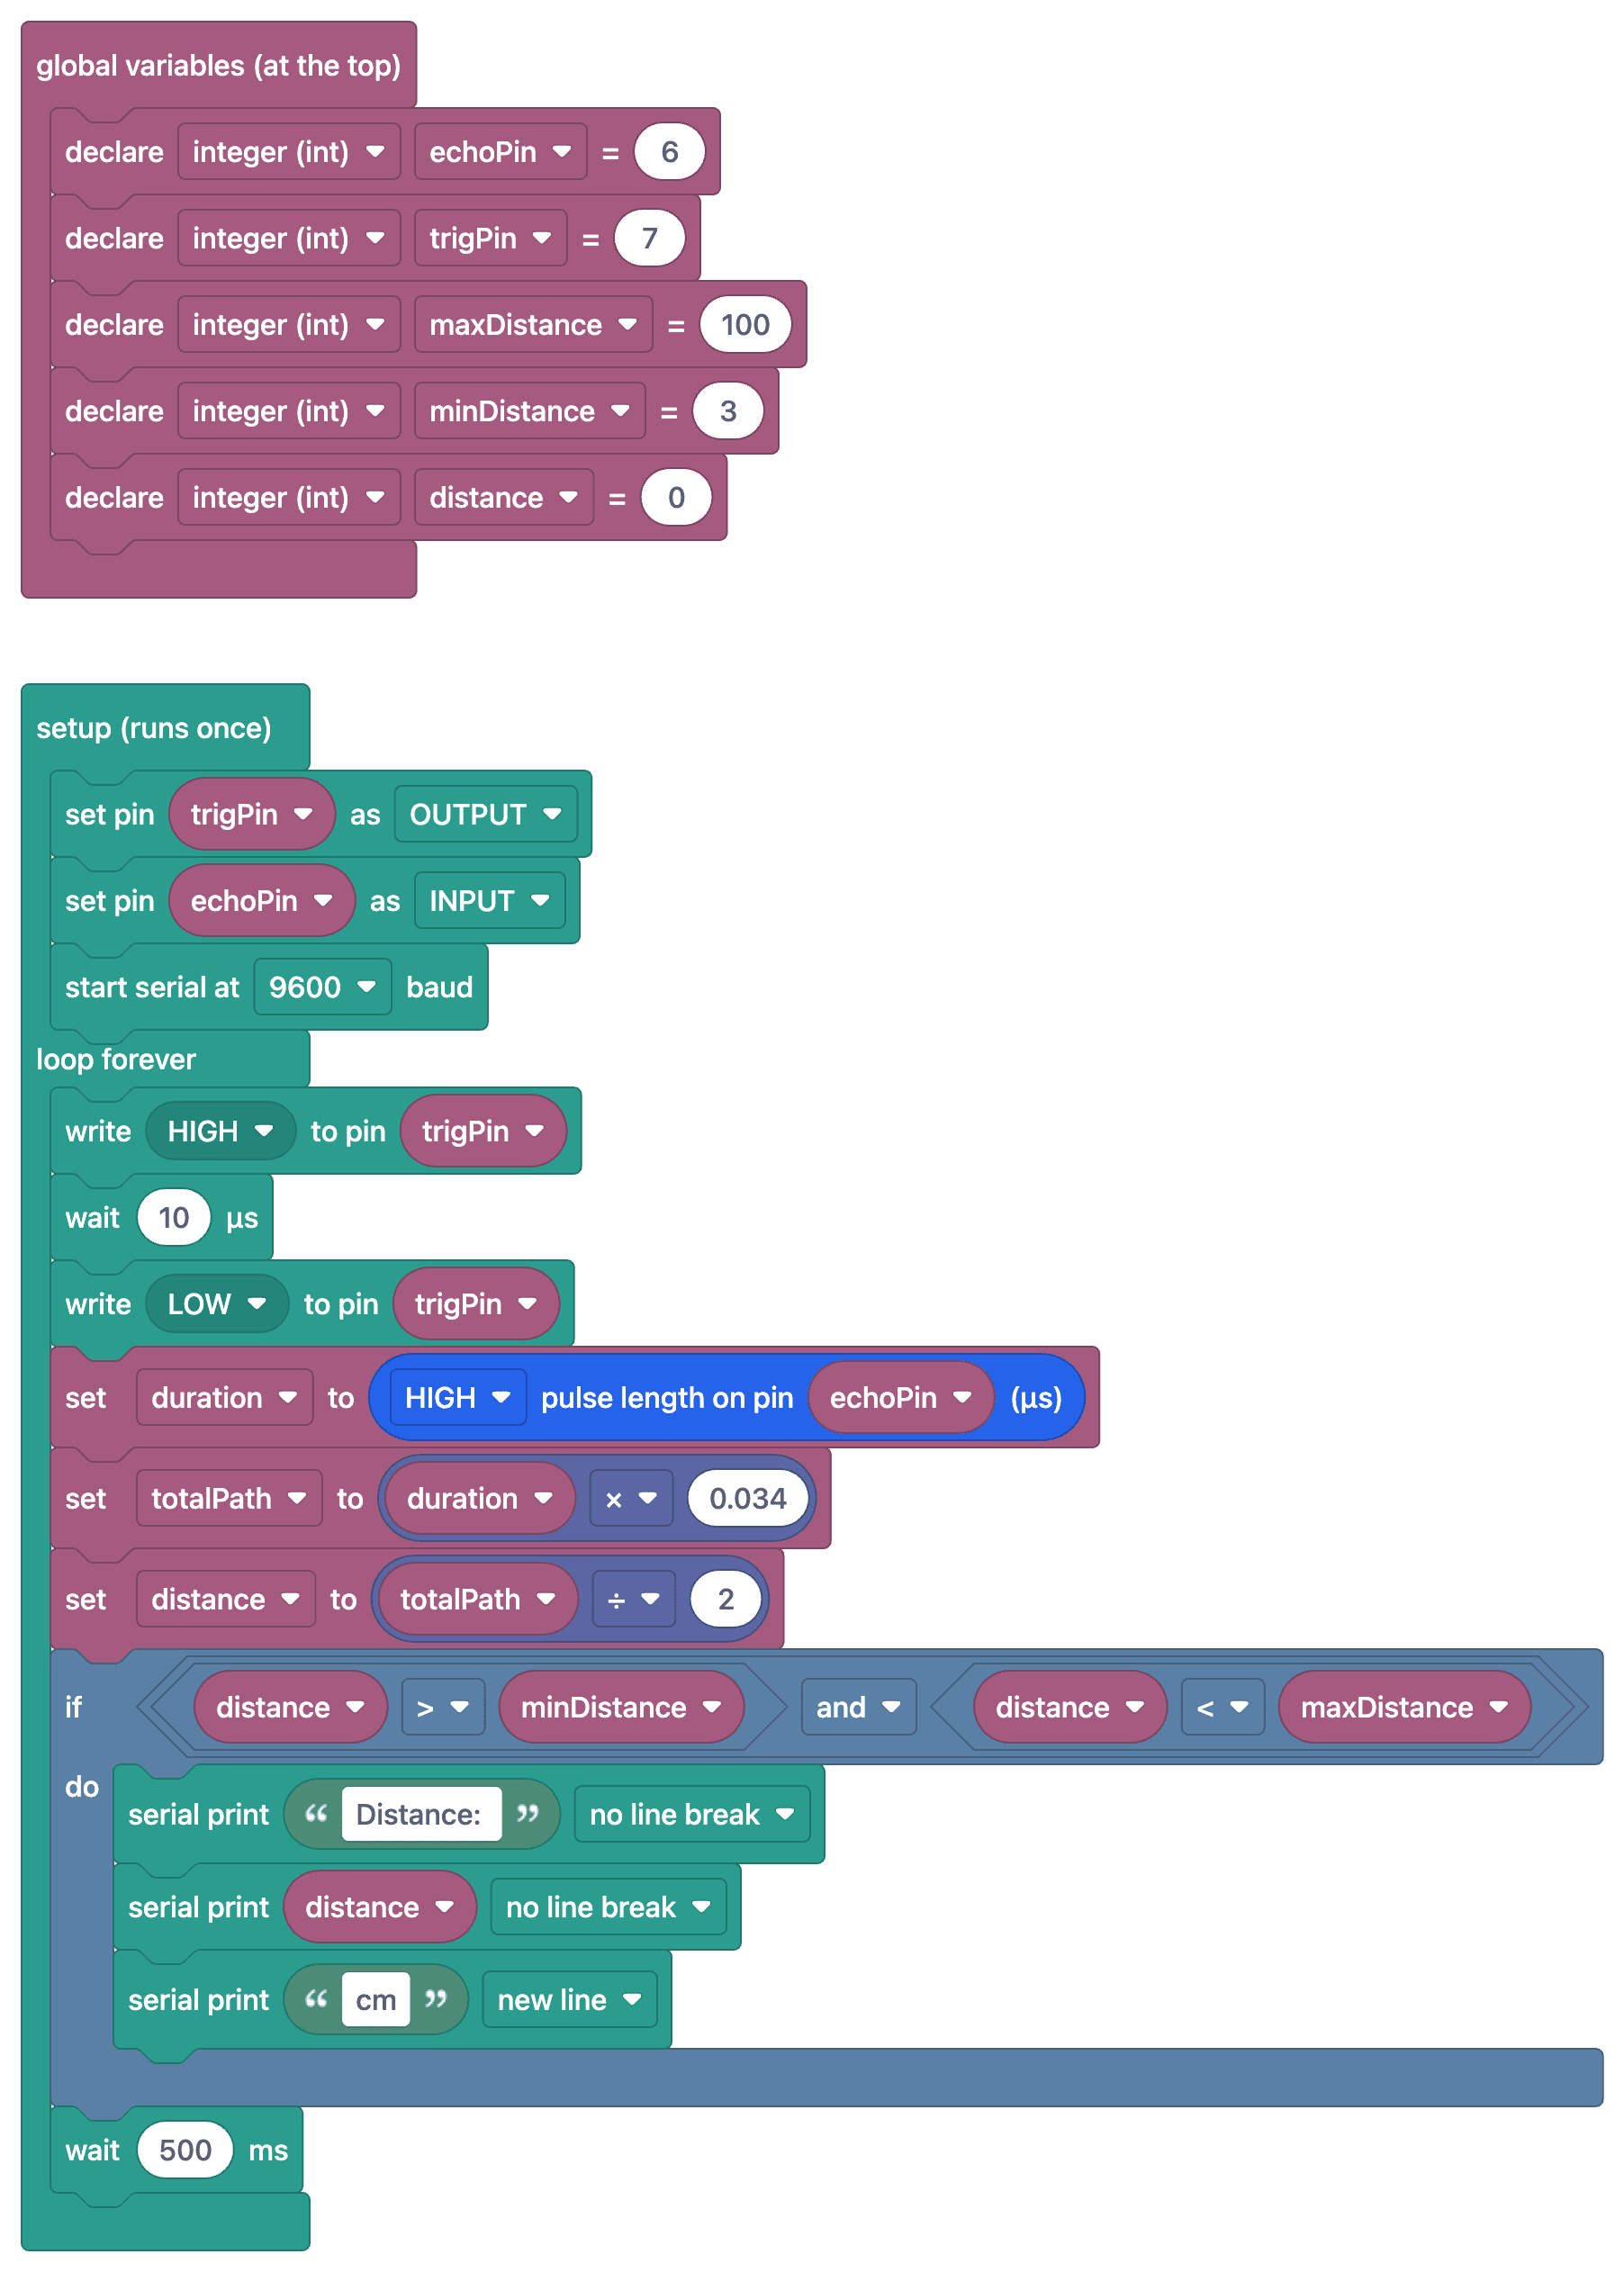
Ko‘p so‘raladigan savollar
How does the HC-SR04 measure distance?
The sensor emits a 40 kHz sound wave and measures the time it takes for the echo to return. Sound travels through the air at a speed of approximately 343 m/s; the distance is converted to centimeters using the formula: distance = time × 0.0343 / 2 (dividing by 2 accounts for the round trip).
What are the shortest and longest distances it can measure?
In practice, it measures distances ranging from approximately 2 cm to 400 cm. Measurements may be inaccurate or read as 0 when the distance is less than 2 cm, or when measuring very far distances or on sound-absorbing surfaces (such as fabric or foam).
Sometimes the readings are 0 or very large—why is that?
If no echo is received, `pulseIn` will time out. Make sure the sensor is facing a flat, hard surface, wait at least 60 ms between measurements, and filter out erroneous readings in your code.
Can I use it with the ESP32?
The HC-SR04 operates at 5 V, and its ECHO pin outputs 5 V. Since the ESP32 operates on 3.3 V logic, you should either add a voltage divider (e.g., 1 kΩ + 2 kΩ) to the ECHO line or use the 3.3 V-compatible HC-SR04P model.