
Teroka Projek Arduino
Ratusan projek dari pemula hingga mahir: gambar rajah litar, kod dan video. Mulakan di tahap mana pun kamu berada.

Bluetooth Controlled Car with L298N
Turn your phone into a remote and drive your own robot car. The Arduino receives commands from a remote-control app on your phone through a Bluetooth module and spins the wheels with a motor driver…

Obstacle Avoidance Robot
How about building a smart vehicle that finds its own way? The Obstacle Avoidance Robot constantly scans its surroundings thanks to the ultrasonic sensor in front of it.

Servo Circle Choreography - Animated Patterns with 32 Servos
A visual animation project driven by 32 servo motors arranged in a circle on an Arduino Mega. The servos are managed in a single array, connected to the Mega's pins 22–53, and perform four motion sequences: a chaotic jitter at random angles, a synchronized sweep, a wave travelling around the circle and a compass needle swinging left and right.

ESP32 RFID Door Lock (RC522 + Servo + OLED + Buzzer + LED)
We build a smart door lock with an ESP32, an RC522 RFID module, an SG90 servo, an SSD1306 OLED display, an active buzzer and 2 LEDs. When a card is scanned, its UID is checked against the authorized cards defined in the code; if it matches, the servo unlocks (green LED + 2 short beeps) and locks again after 5 seconds. An unknown card lights the red LED, gives 3 quick beeps and shows its UID on the OLED.

ESP32 PID Ball and Beam (HC-SR04 + Servo + I2C LCD + 3 Potentiometers)
The classic control engineering experiment on your desk: a servo tilts a beam and PID holds the ball on target. Three potentiometers change Kp, Ki and Kd live: with P alone the ball swings, D damps it and I cancels the beam's slight lean so the ball lands right on target. The I2C LCD shows the beam, ball and target, plus settling time and overshoot. In SIM mode a physics model rolls the ball; in REAL mode an HC-SR04 measures it.
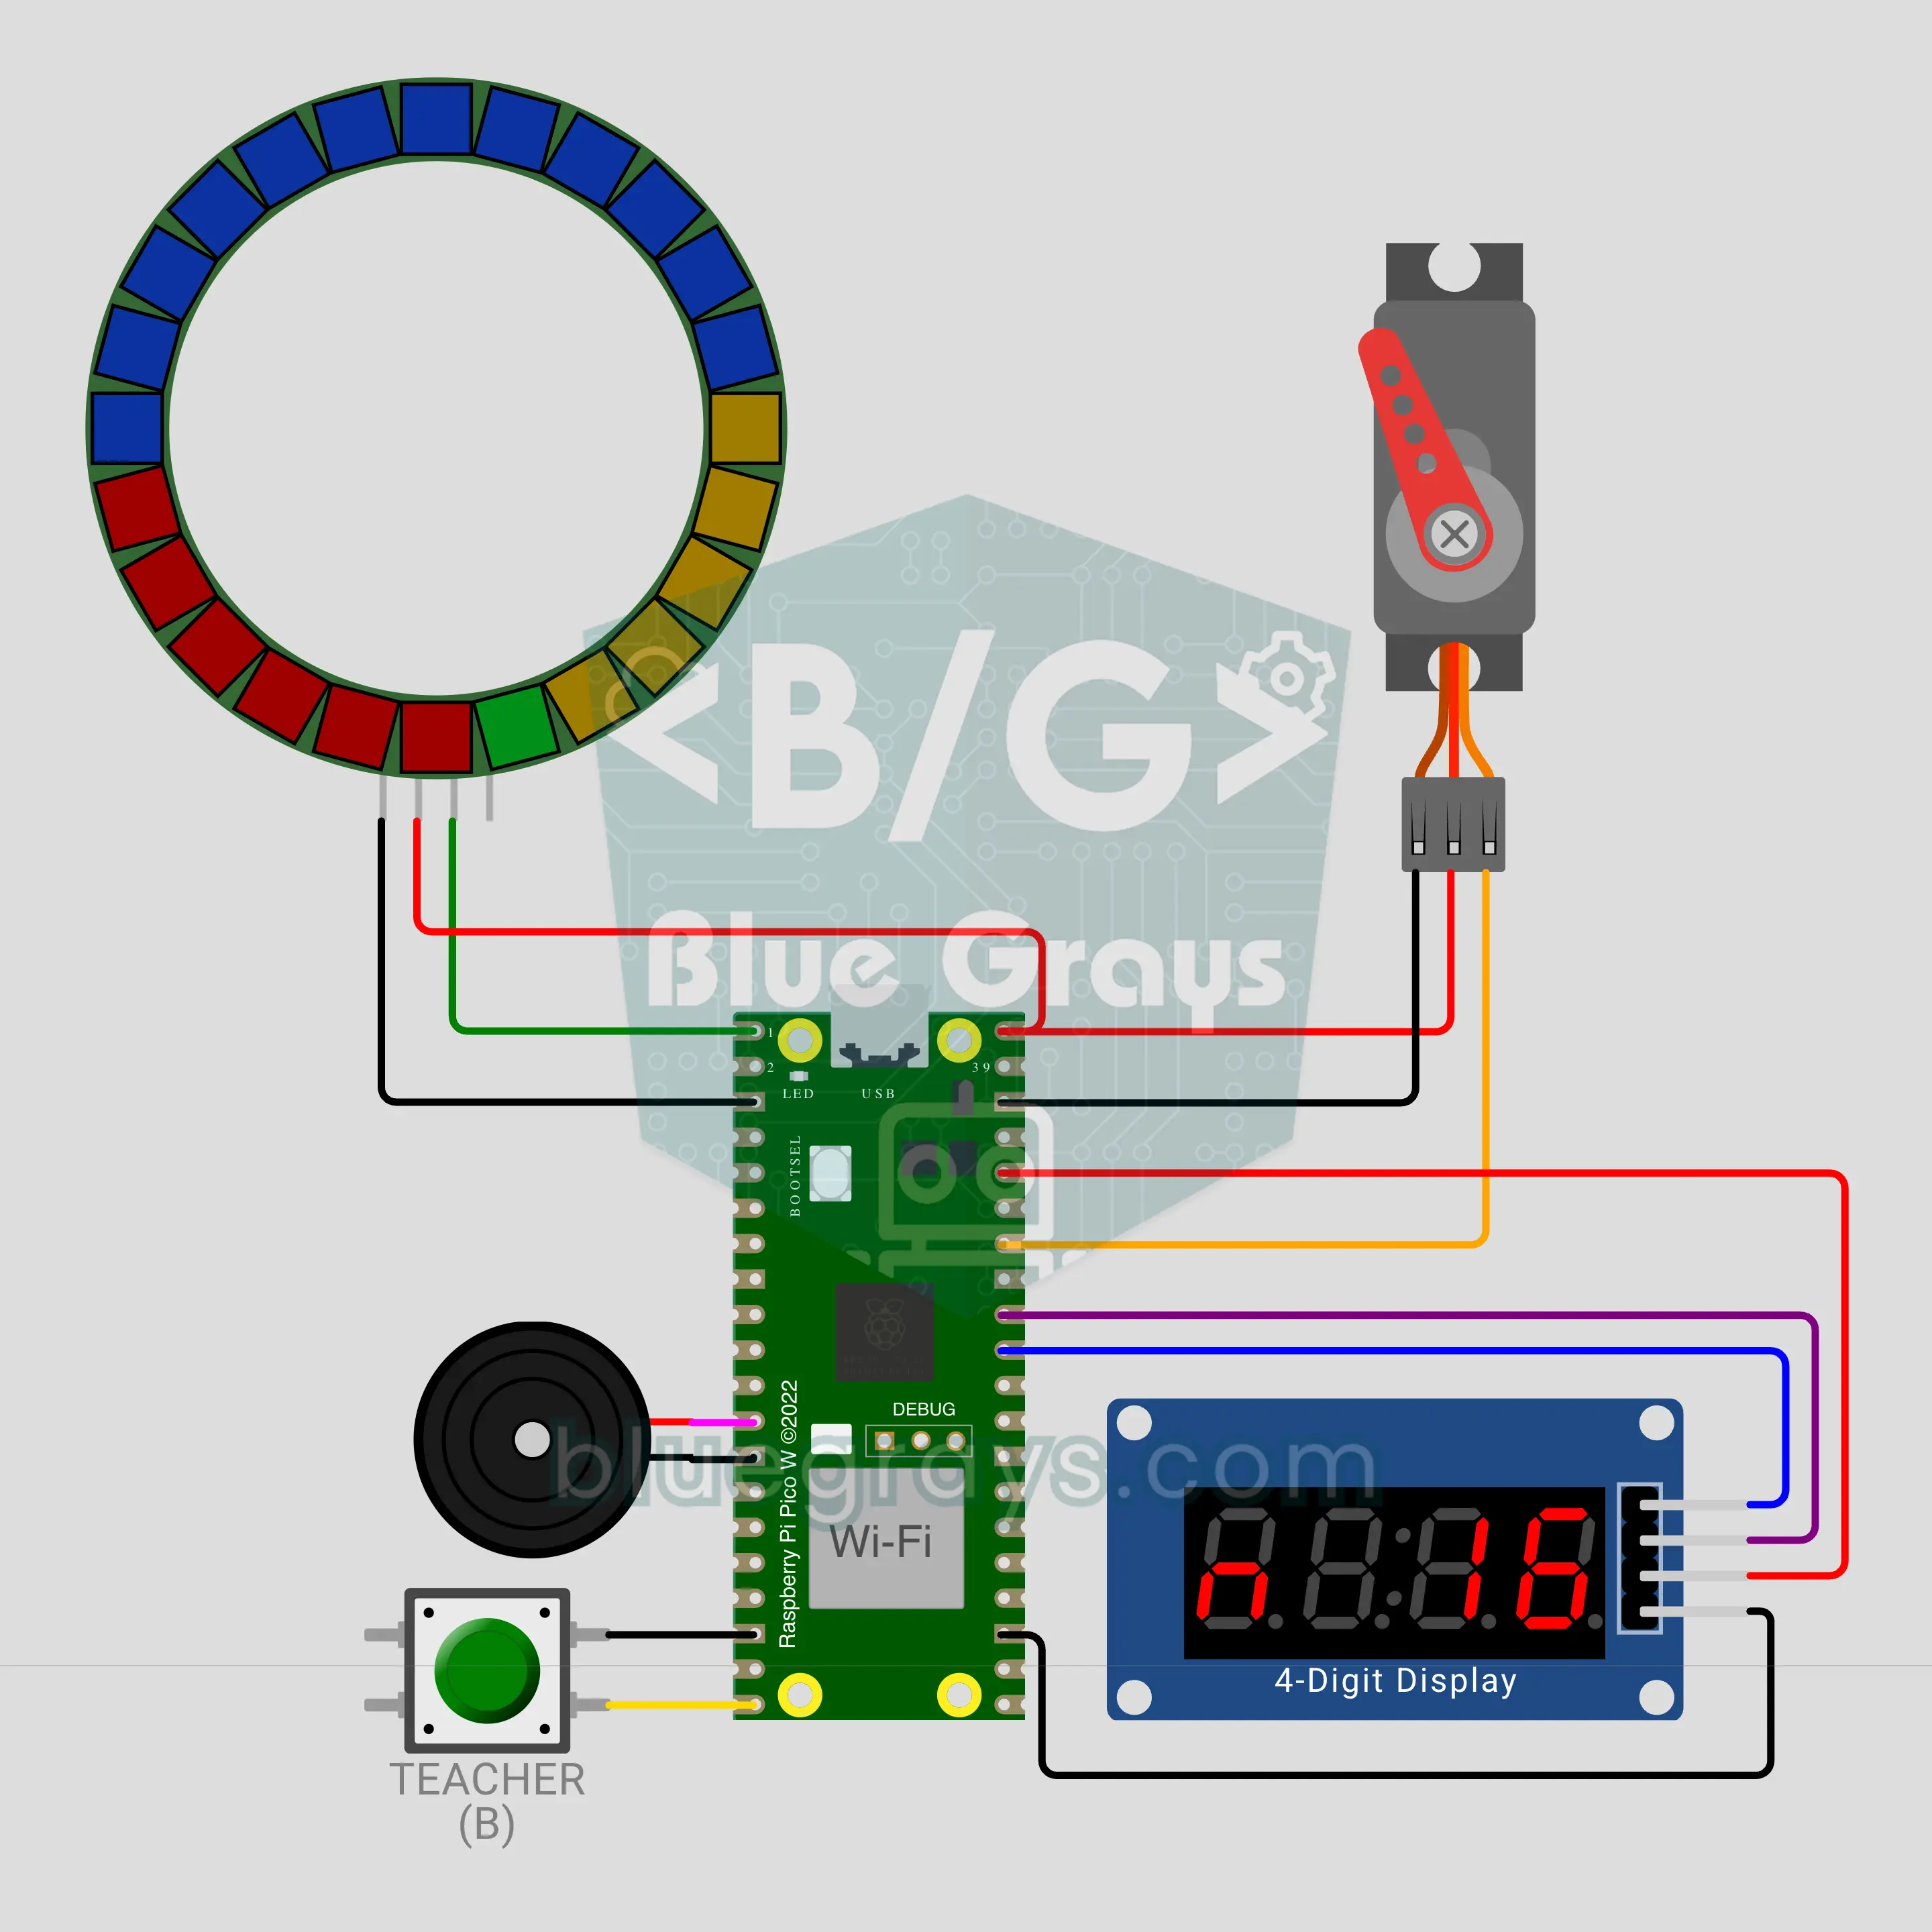
Raspberry Pi Pico W Live Classroom Poll (MQTT + LED Ring + SG90 Servo + TM1637)
See the whole class's answer the moment it comes in! The Raspberry Pi Pico W collects A/B/C/D or YES/NO votes from students' phones over MQTT; the 24-LED ring becomes a live pie chart, an SG90 servo needle points at the leading option and a TM1637 counts the votes. One vote per phone, and if someone changes their mind only the last vote counts. Timed questions beep through the final 5 seconds, and closing a question makes the correct option glow.
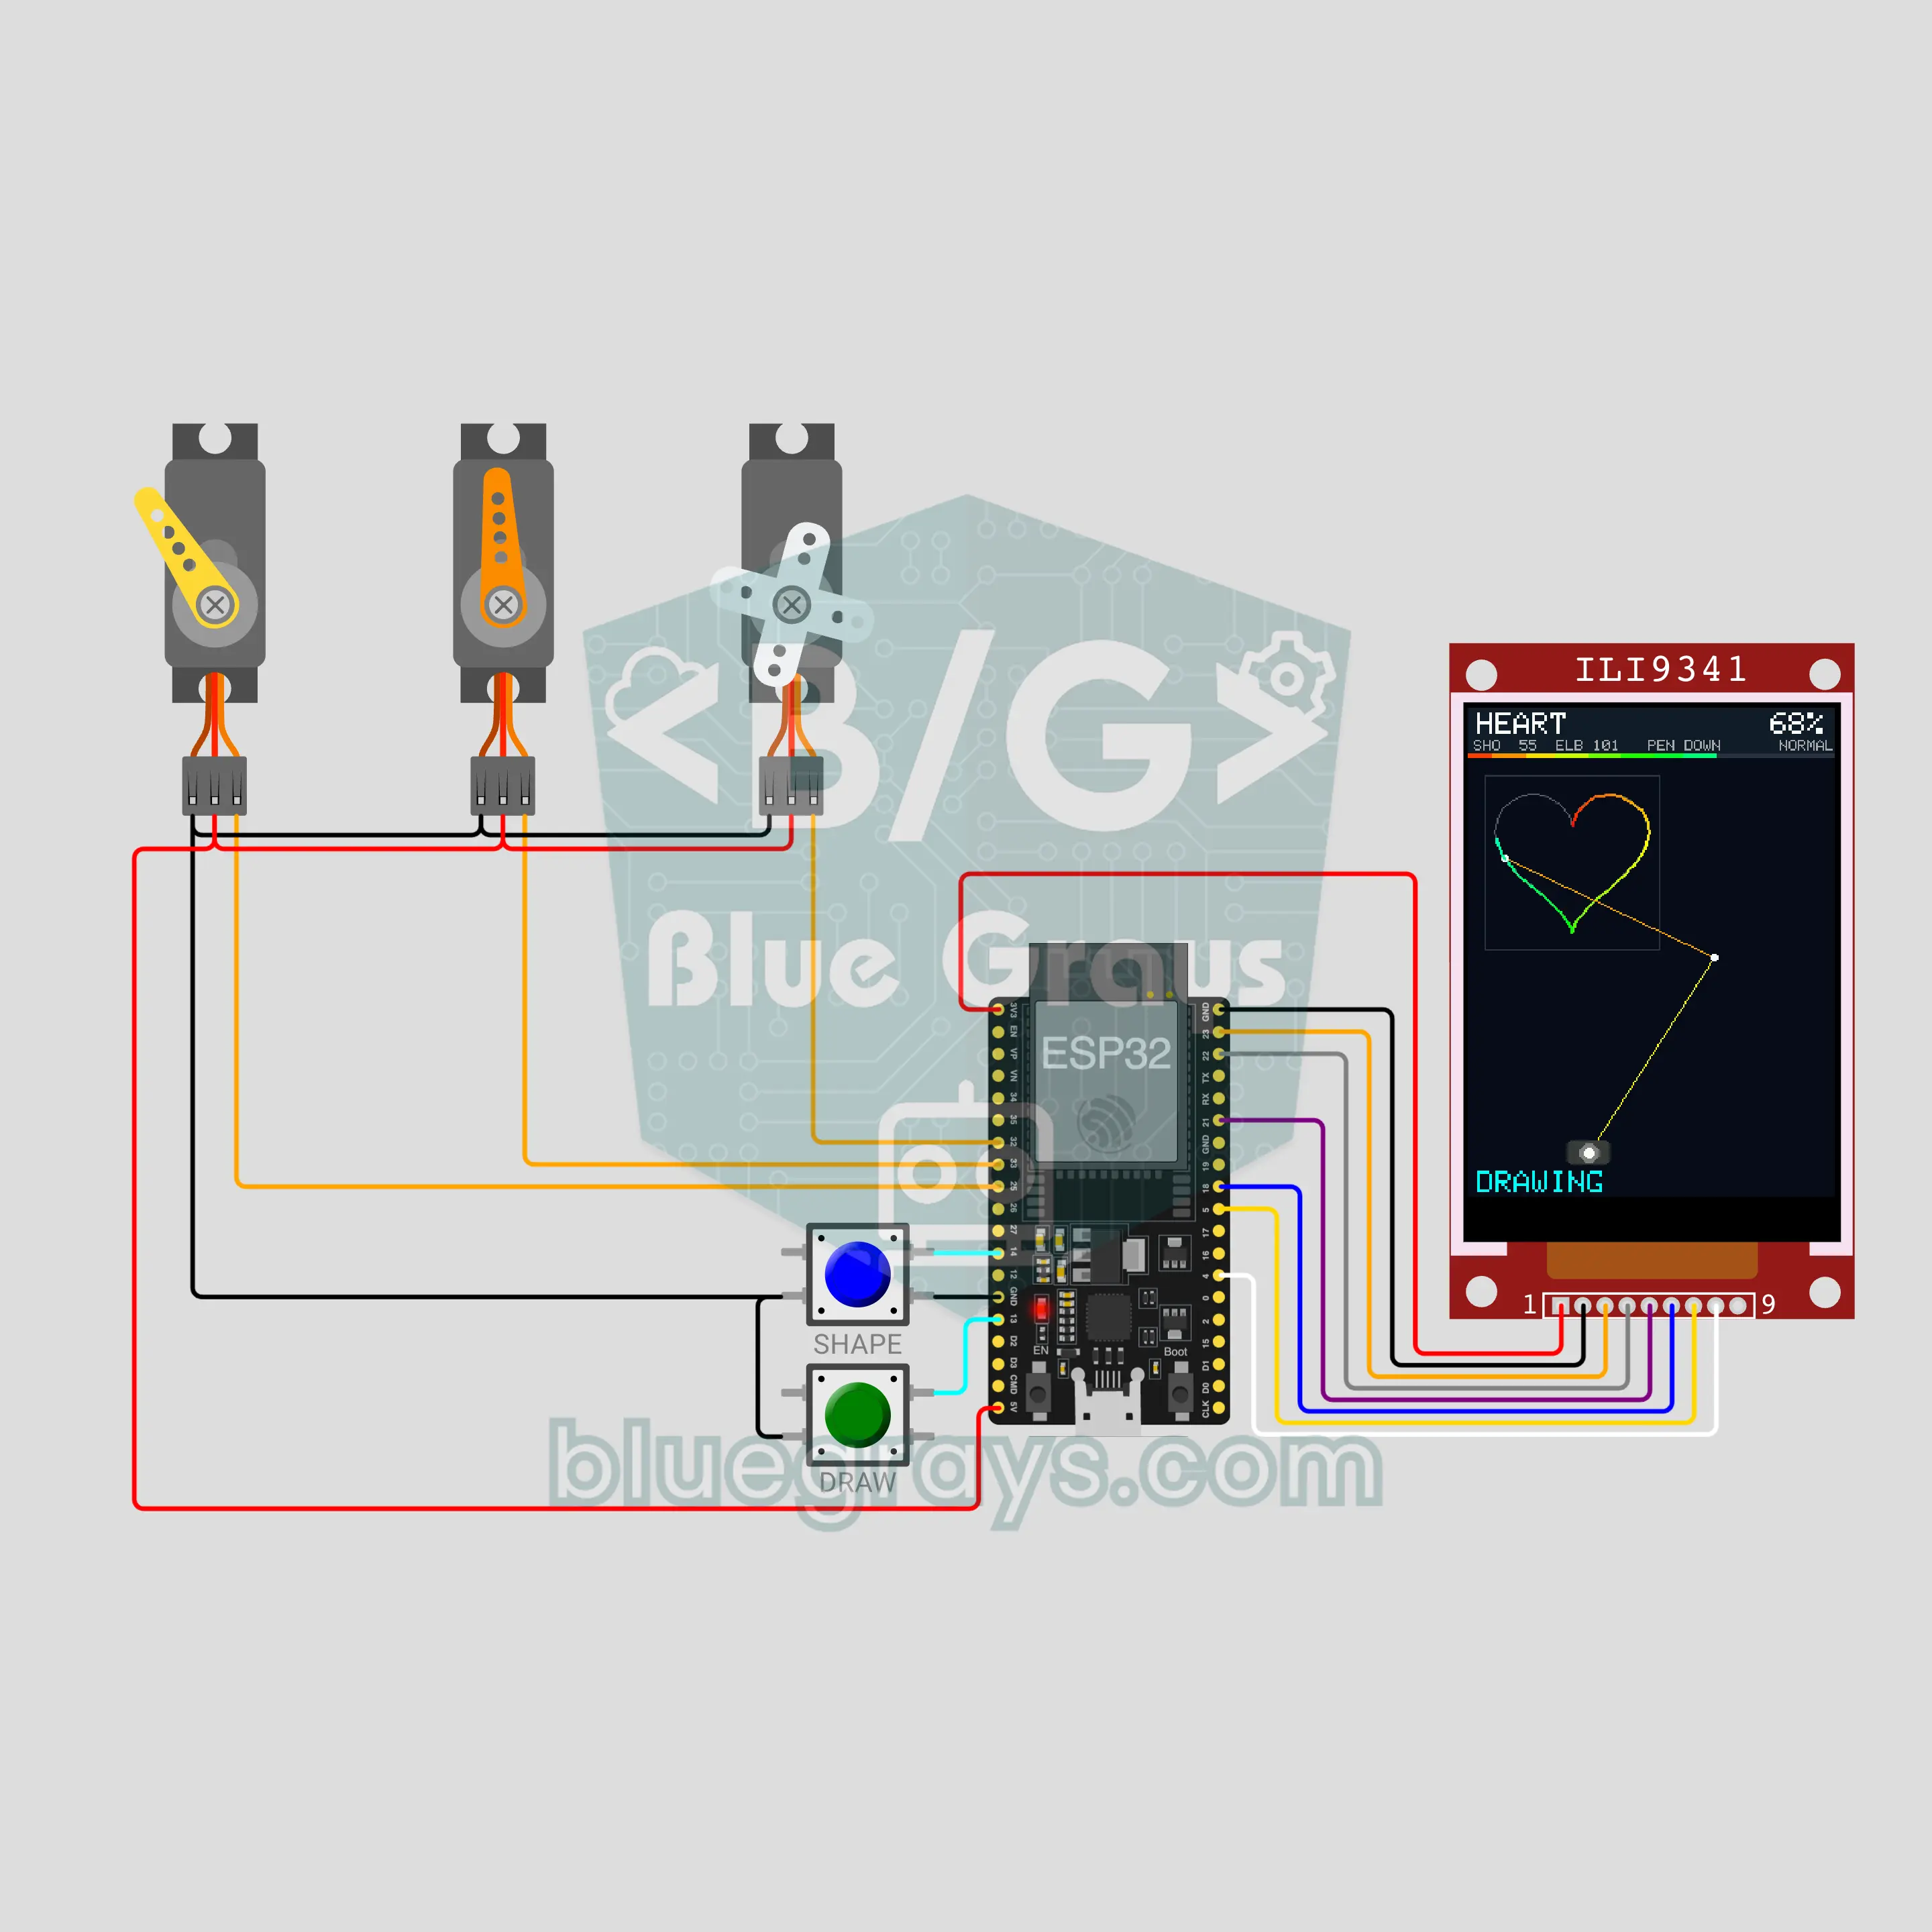
ESP32 Drawing Robot Arm (3 Servos + ILI9341 TFT Display + 2 Buttons)
A two-joint robot arm draws a heart, a star, a house, a spiral and the word MERHABA on paper, while a third servo lifts and lowers the pen. The ESP32 turns every point into shoulder and elbow angles with inverse kinematics and moves the arm in 0.5 mm steps; if a point is out of reach, it shows OUT OF REACH. The ILI9341 display shows the faint target, the arm moving live and a trace that shifts from red to blue. Two buttons: shape, pause, cancel and speed.

Arduino Industrial Sorting Conveyor: Boxes Sorted by Height (NEMA 17 + A4988 + HC-SR04 + Servo + LCD)
A desktop model of a factory sorting line: a NEMA 17 stepper on an A4988 driver keeps the belt moving, and an HC-SR04 above the belt measures the height of every passing box. Each box is tracked by belt steps from the sensor to the arm; boxes of 6 cm and up are pushed aside by an SG90 servo arm, low ones carry on. The I2C LCD counts short and tall boxes and shows the last reading and how many boxes are on the belt.

Arduino Industrial Mixing Tank: Fill, Mix, Drain with PLC Logic (HC-SR04 + 2 Relays + NEMA 17 + A4988 + LCD + E-Stop)
The classic batch process task from industrial automation classes: fill the tank, mix, drain, count the batch. The code runs step by step with PLC logic (S0 IDLE → S1 FILL → S2 MIX → S3 DRAIN → S4 DONE). Two relays open the inlet and outlet valves, an HC-SR04 measures the level and a NEMA 17 mixer turns and reverses. It has START, STOP, a latching EMERGENCY STOP, a tower lamp and a timeout fault.

ESP32 Robot Vacuum Cleaner: Turns at Obstacles and Maps the Room (2 NEMA 17 + 2 A4988 + HC-SR04 + 2 Bumpers + OLED)
A two-wheeled robot vacuum cleaner that moves like the real thing. Two NEMA 17 steppers turn the wheels: it draws a spiral, drives straight, slows down and turns when the HC-SR04 sees an obstacle, backs off and turns away when a bumper hits, and does an edge lap along the walls. It works out its position from the wheel steps and shows a map of the room on the OLED with the cleaned percentage and time, then drives back to its start.
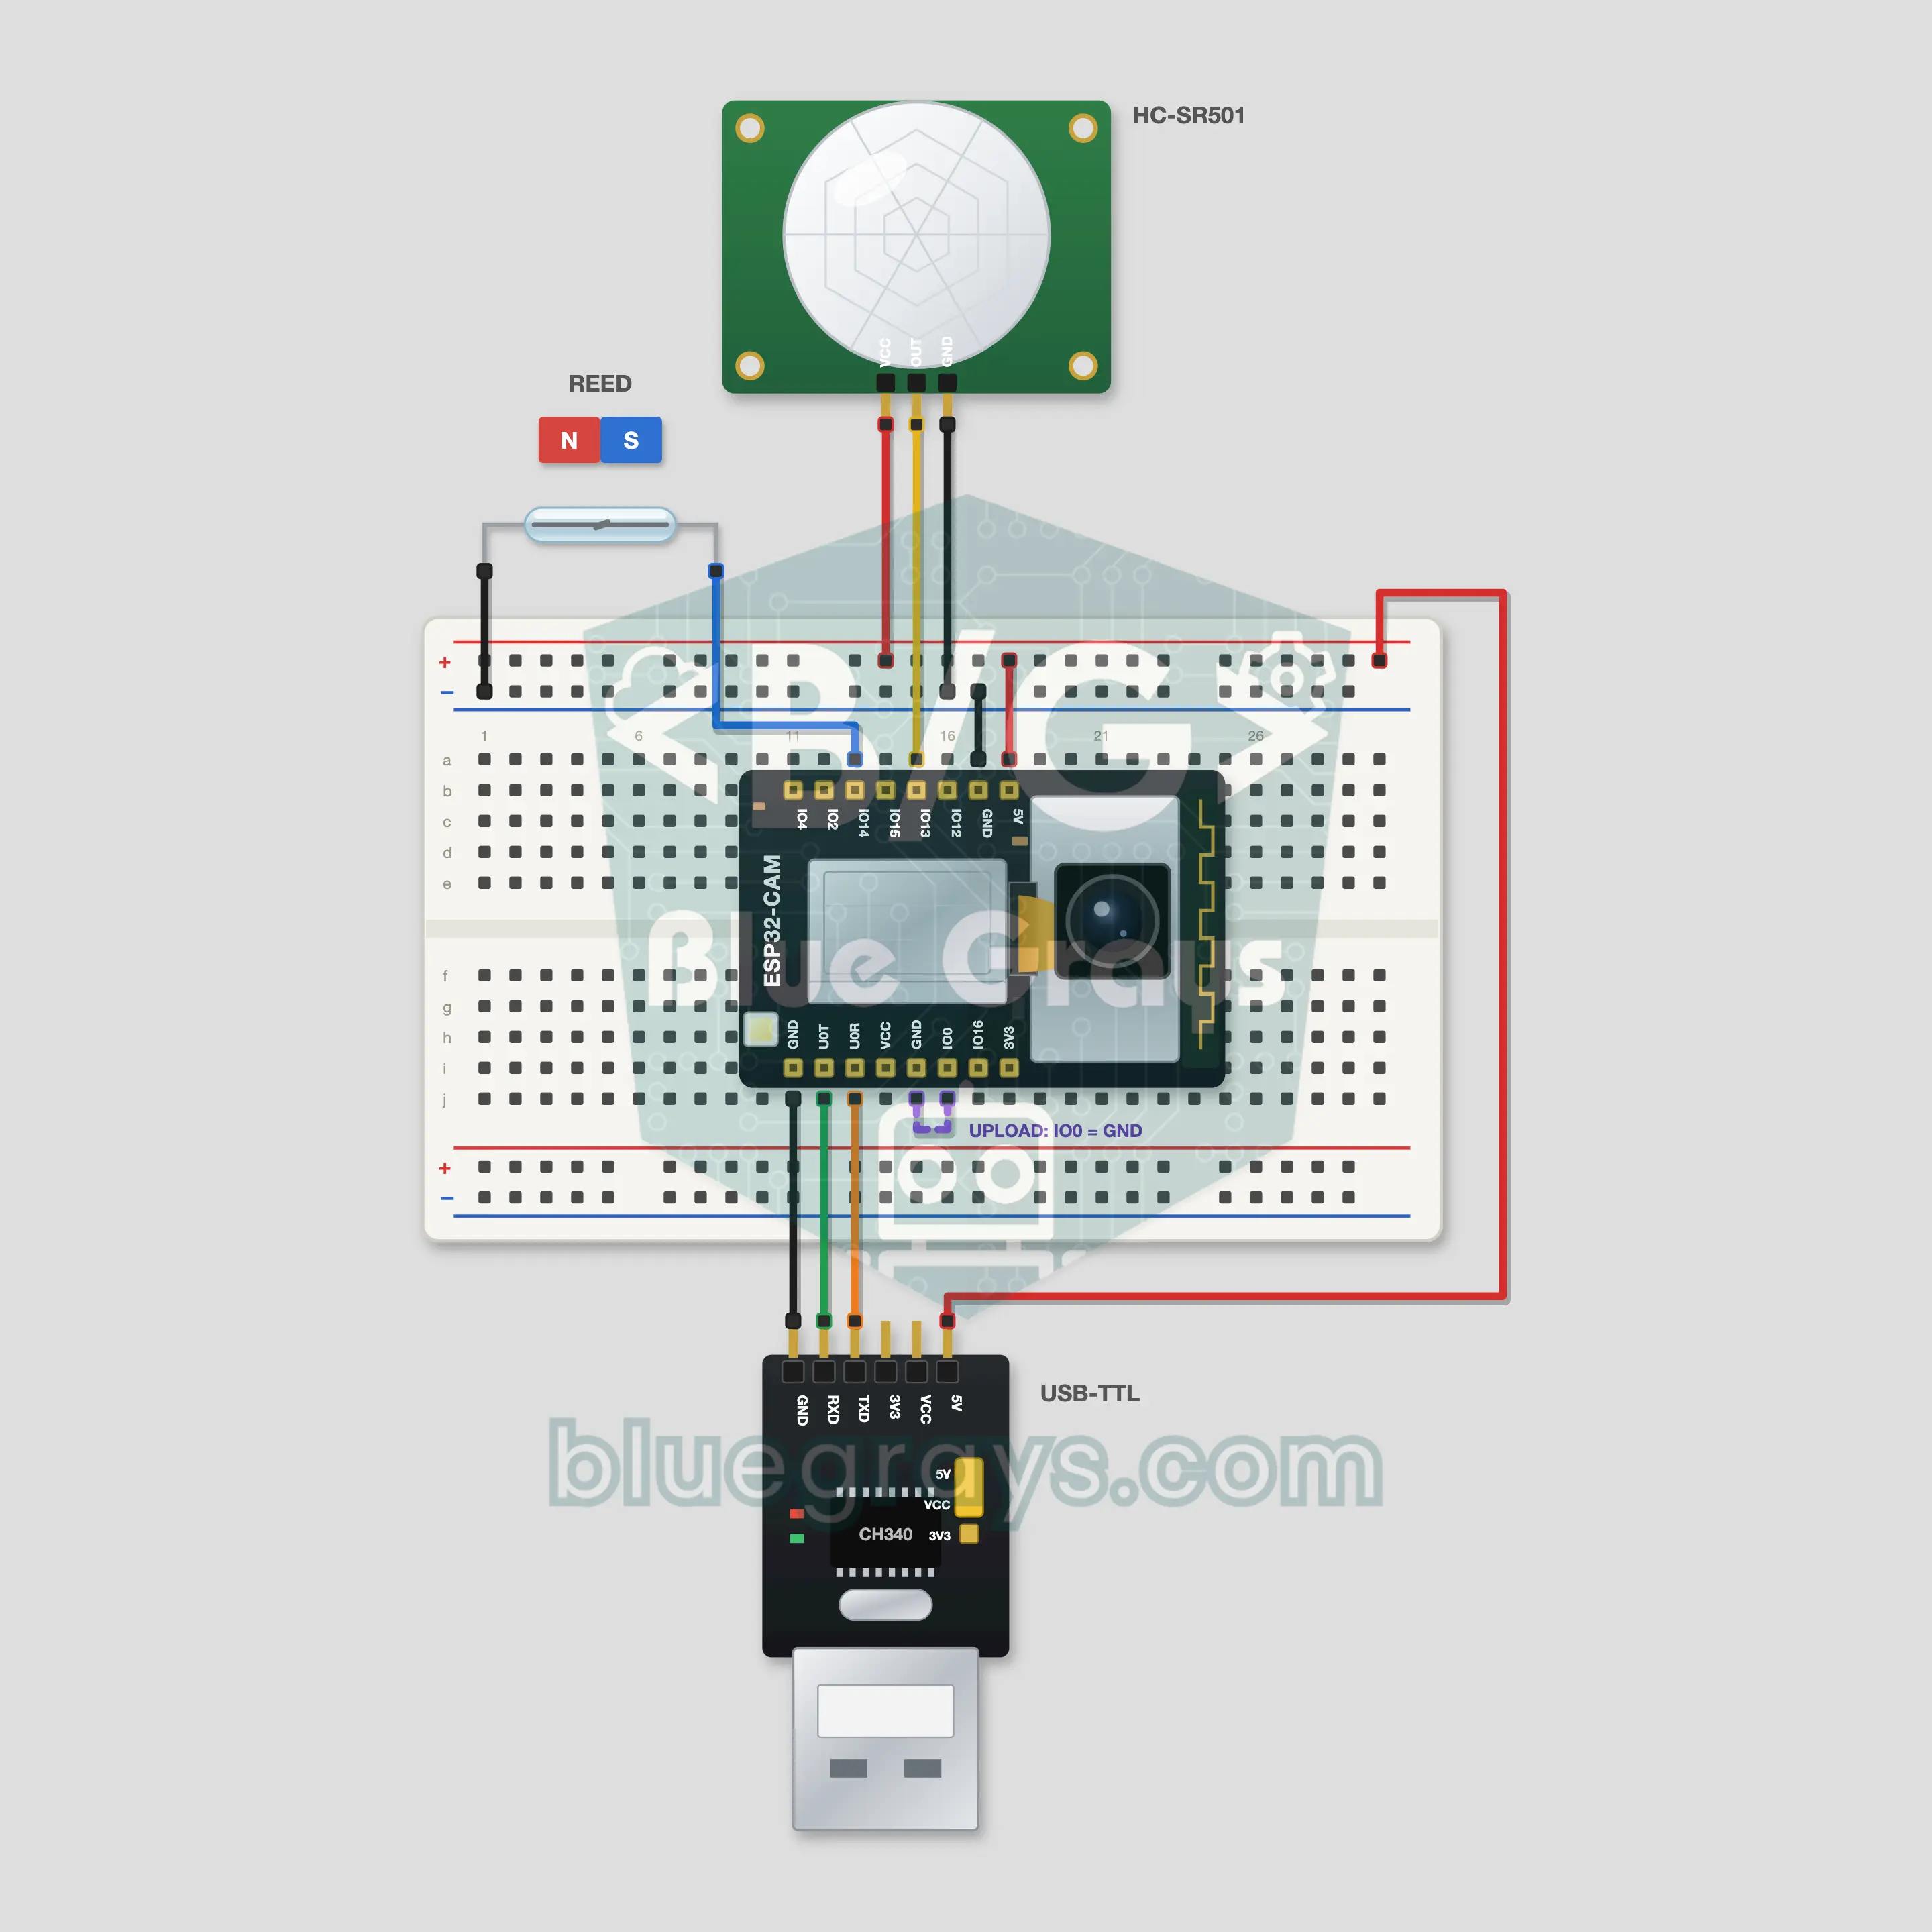
ESP32-CAM Telegram Security Camera
When your door opens or something moves in the room, the ESP32-CAM takes a photo and your Telegram bot sends it to your phone. A reed switch and magnet guard the door, a PIR HC-SR501 watches the room. Type /photo to the bot for a photo on demand; /flash on, /alarm off and /status run the camera from anywhere. The bot only listens to your own chat id. You get the token from @BotFather; the steps are in the FAQ.